 NYX
Three systems, one stack.
Each one runs on AMD adaptive silicon inside the vehicle, with no cloud service in the loop.
ANAX
Perception, sensor fusion and control on a single module, flown on fixed-wing, multirotor, ground and legged platforms and extended to a five-aircraft swarm.
Guidance core
Seeker fusion, state estimation, proportional navigation and autopilot, implemented in logic and sized for a low-cost interceptor.
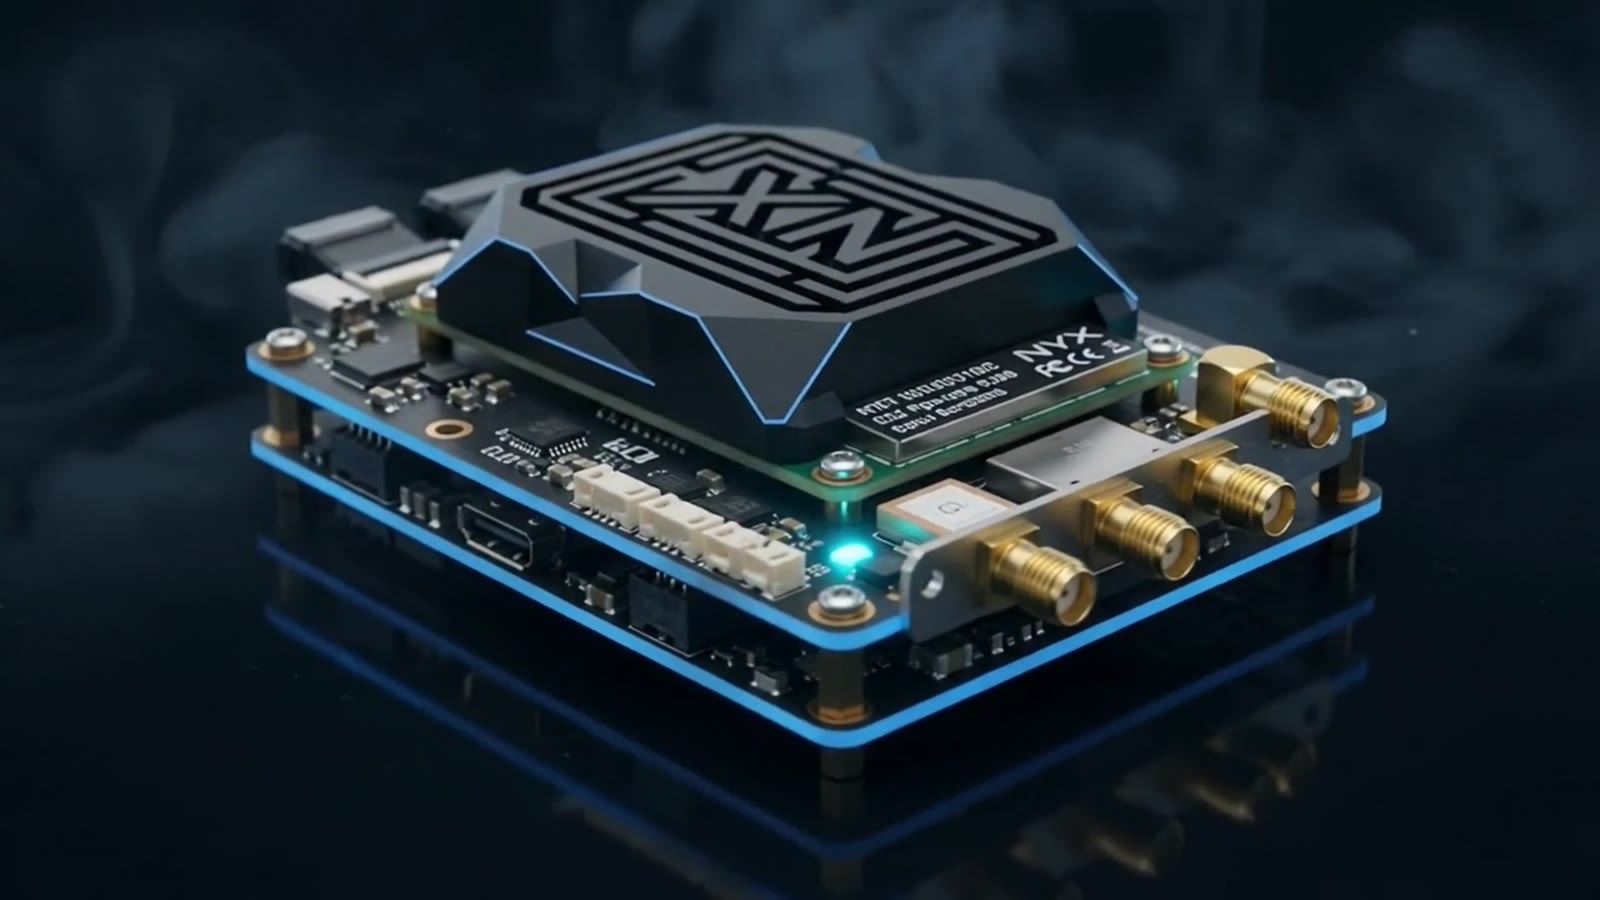
NyxCore
Language models built into FPGA logic, answering from grounded sources where there is no cloud and no link.
How we choose the tools
We design custom logic sparingly, and we will tell you when you do not need it.
Custom logic on AMD adaptive silicon, where physics leaves no alternative
Some loops cannot be closed by general-purpose compute at any price. When the budget is set by the airframe or the vehicle rather than by the software team, the compute has to change shape.
- Guidance and control loops with bounded, deterministic timing
- Platforms constrained by size, weight and power
- Contested or disconnected environments, air-gapped by design
Integration, everywhere else
Most of the time the constraint is ownership of the working system rather than compute. We integrate on whatever silicon fits your program, and we stay on the hook for it.
- Architecture, controls, firmware and application software as one program
- Open interfaces: ROS 2 and MAVLink, with a message architecture aligned to modular open systems practice
- Support that outlives the integration
Where the compute lives
Every Nyx system runs on AMD adaptive platforms, chosen to fit the power budget of the machine.
| Platform | Role | What runs there | Status |
|---|---|---|---|
| AMD Kria K26 SOM / KV260 | Autonomy and vision | Perception, sensor fusion and control for air, ground and legged platforms | In use |
| AMD Kria KD240 | Motion control | Real-time drive and actuator control at the point of actuation | In development |
| AMD Alveo U50 | Language model inference | Ternary language models with grounded retrieval on a single card | In use |
| AMD Versal adaptive SoCs | Next generation | Larger models and multi-sensor fusion at the edge | Roadmap |
Status labels are literal. In use means deployed and measured. Roadmap means a target we have not yet demonstrated.